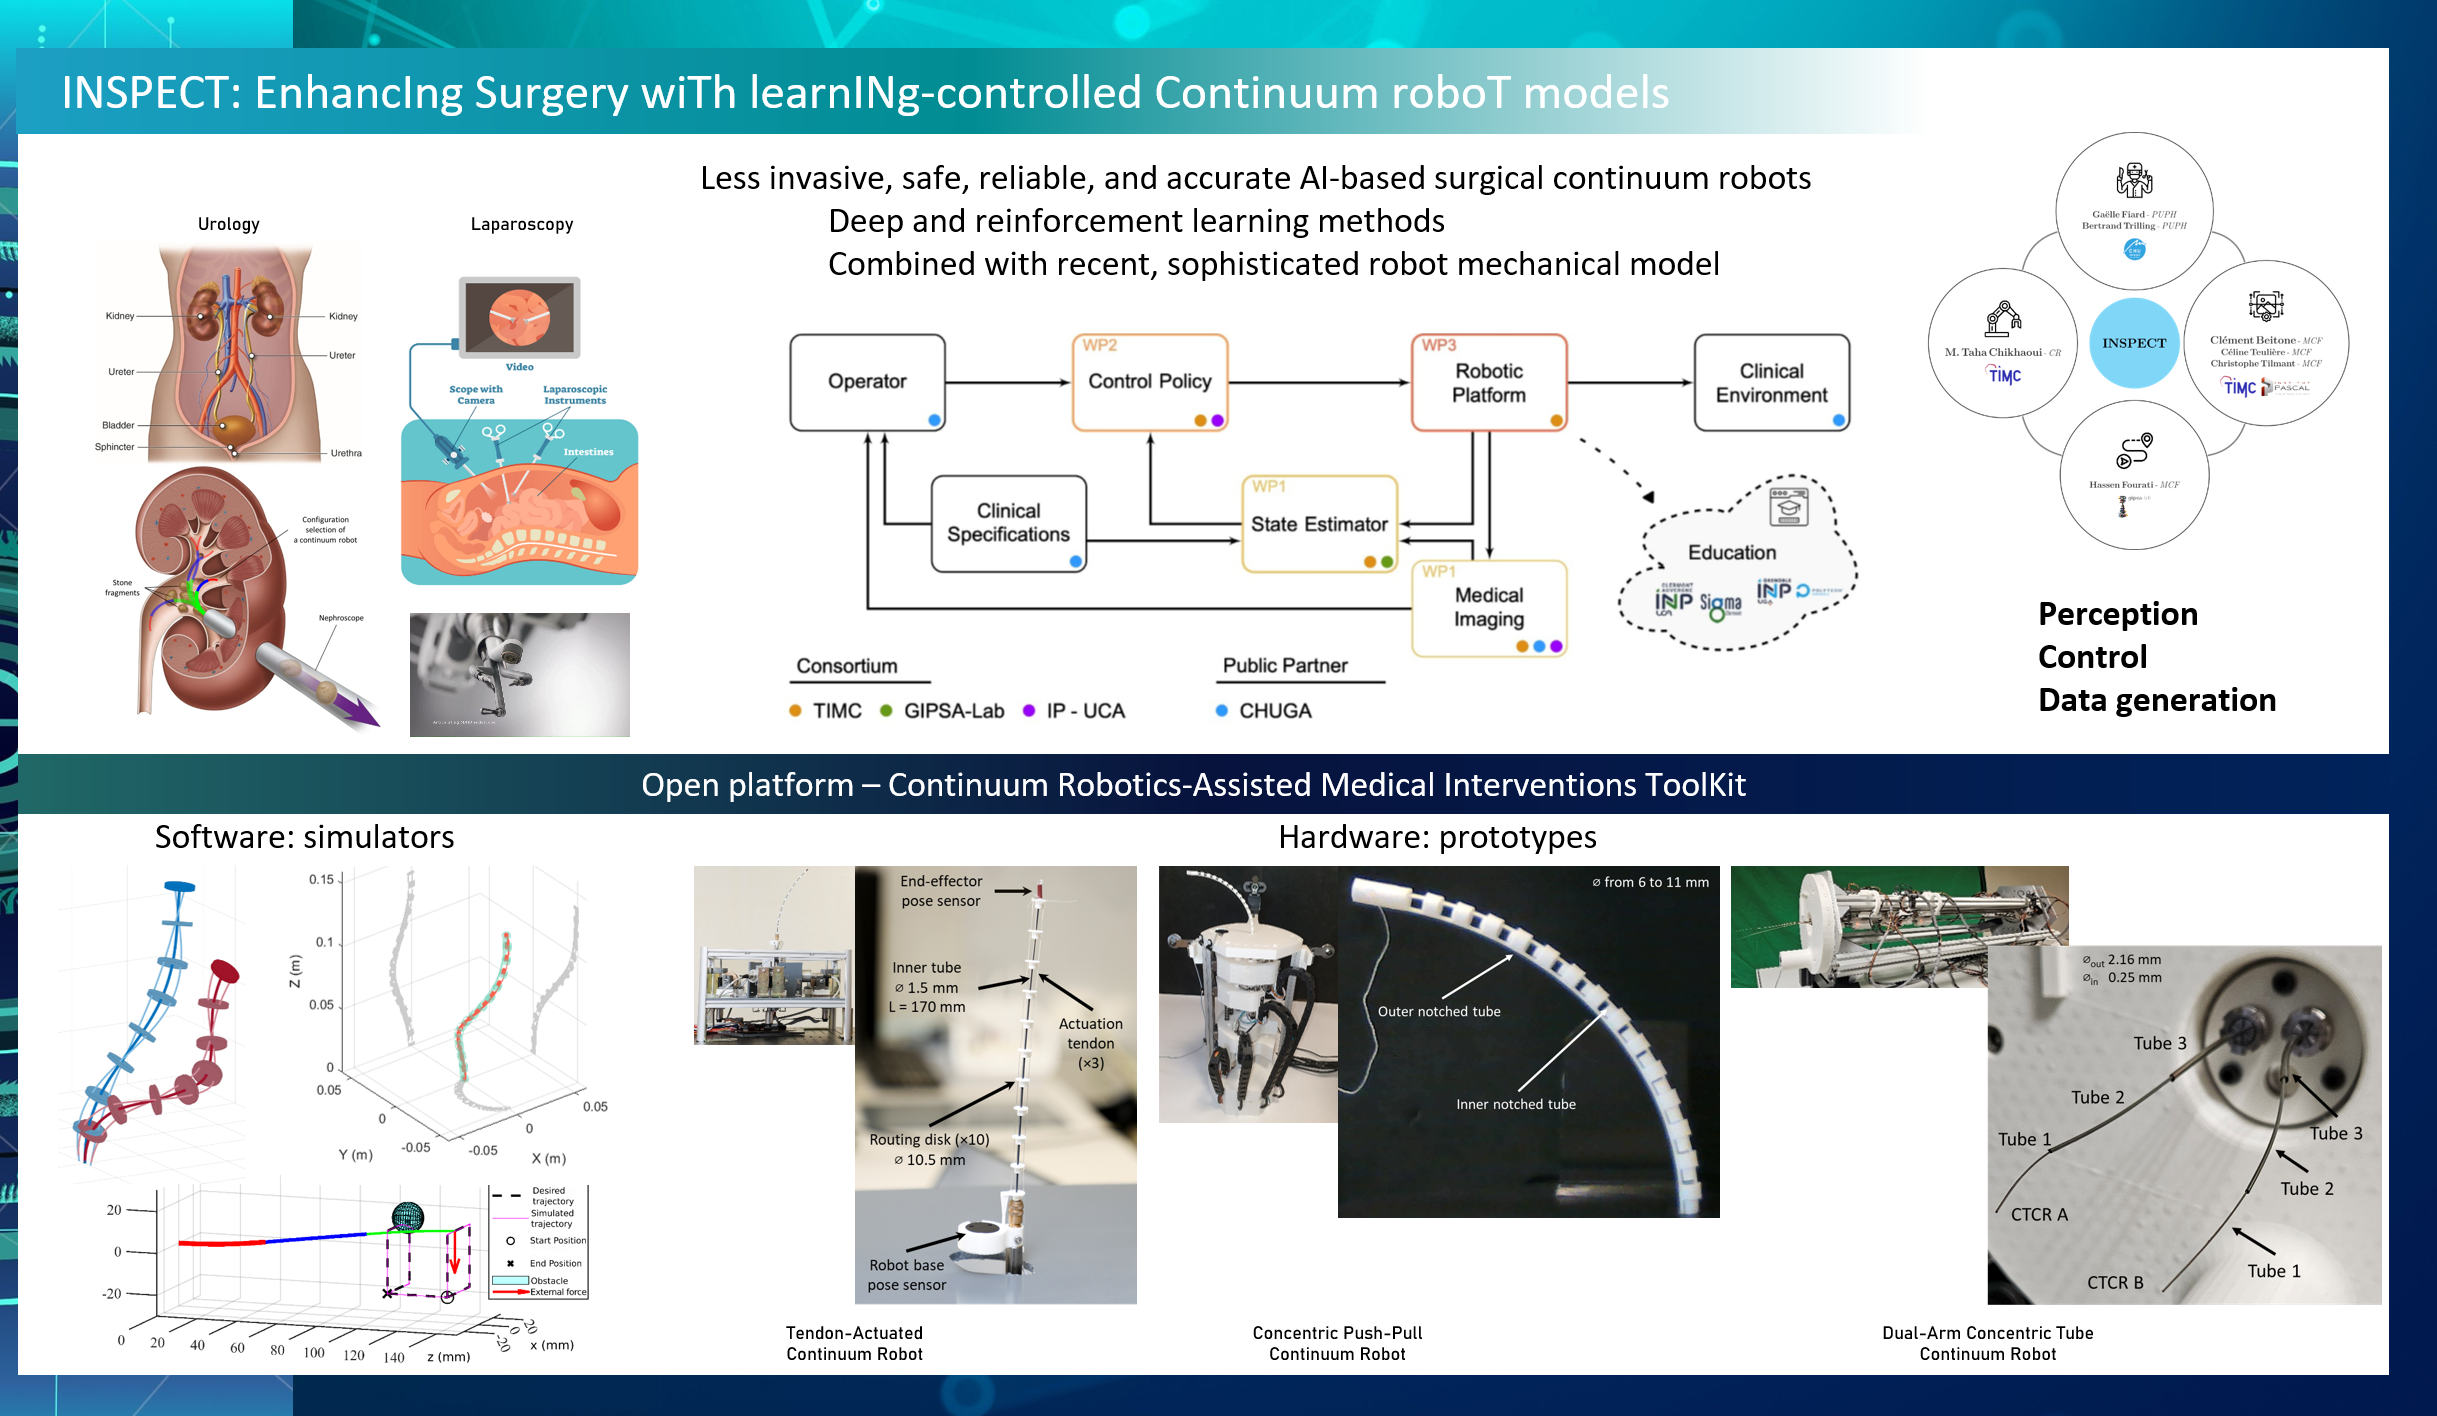
Developing reliable and explainable artificial intelligence (AI) approaches is of paramount importance, especially in clinical applications. The widespread adoption of surgical robots is well established, with a market projected to reach $16 billion by 2024. This field has been shaped by the introduction of continuum robots in recent decades—a breakthrough in the robotics paradigm—enabling inherently safe, miniaturized, and deformable systems capable of accessing and navigating complex anatomy and precisely reaching confined therapeutic targets. However, their widespread use is still limited by the ability to localize and control such small devices in medical images. INSPECT will provide AI (deep learning and reinforcement learning) methods, combined with recent sophisticated mathematical models of robots, to precisely estimate the entire shape of continuum robots and assist surgeons in accurately controlling their motion. INSPECT will aim to advance AI-based surgical robots, making them less invasive, safer, more reliable, and more accurate.
September 23, 2025
The INSPECT Chair made a presentation at the UGA International Advisory Board Meeting and received positive feedback from the international community.