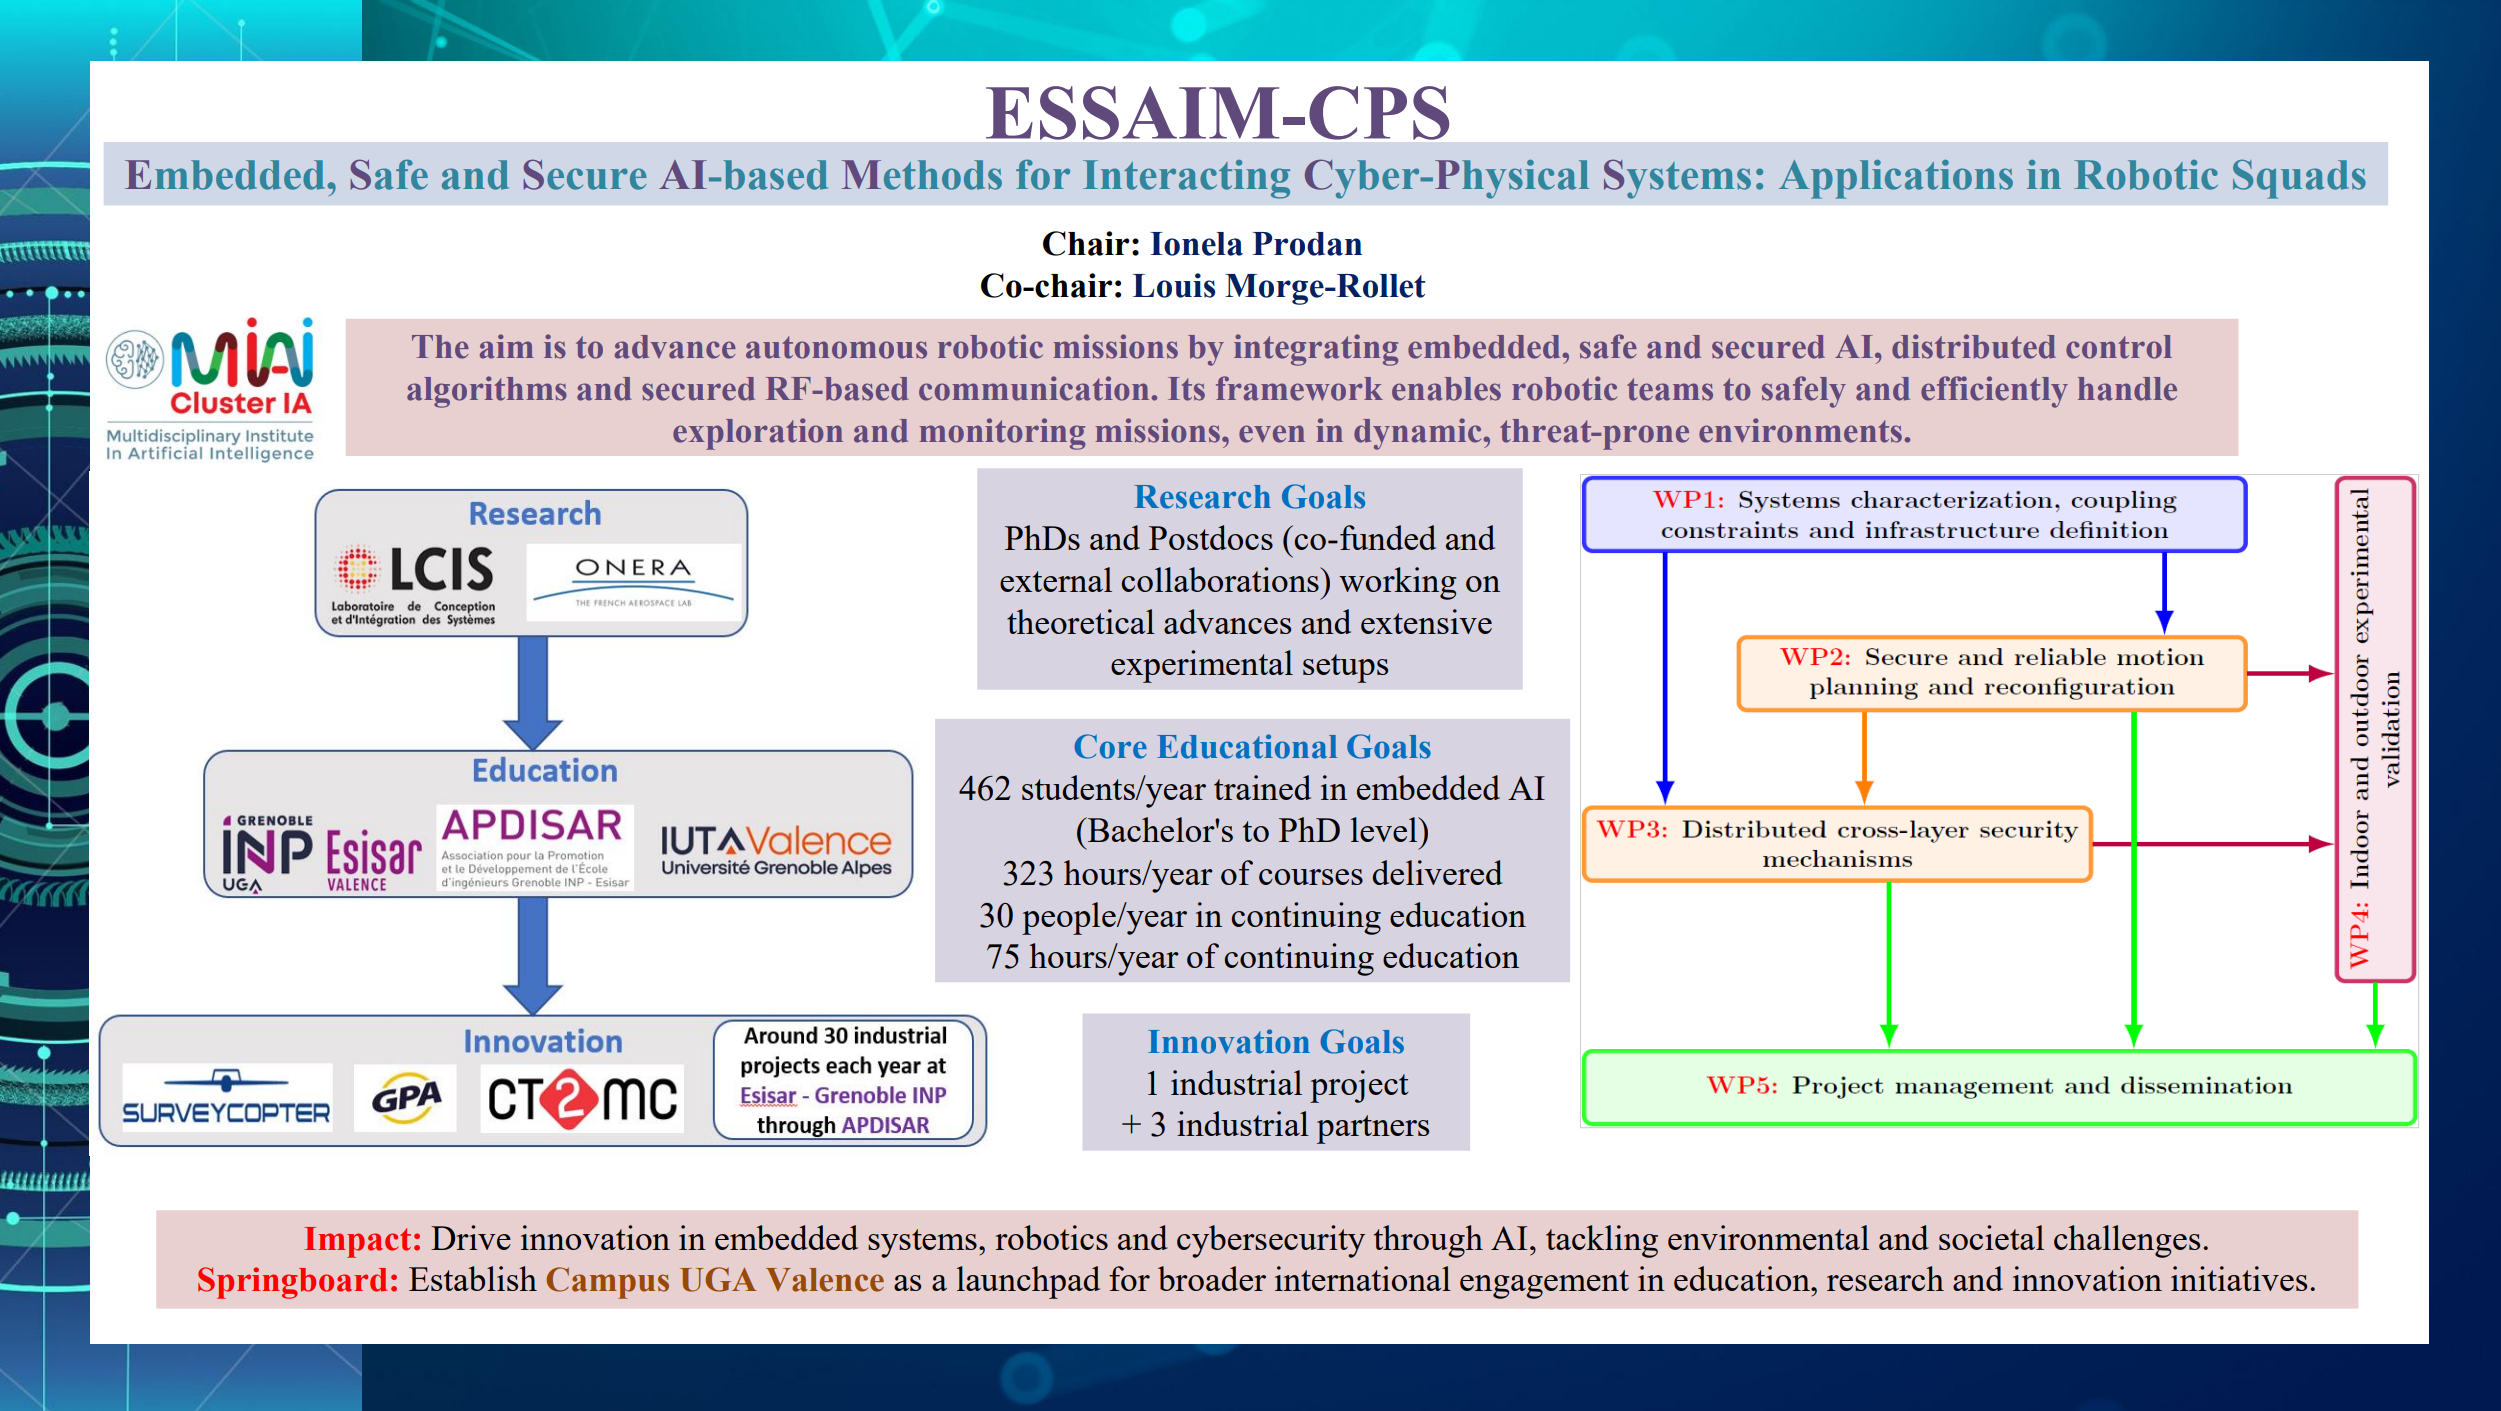
In modern applications, robotic squads—collaborative groups of terrestrial and aerial robots—are deployed in exploration and monitoring missions, ranging from industrial inspections to disaster response and space exploration. These missions rely on interacting cyber-physical systems (CPSs), in which robots communicate and operate through sensors and controllers as embedded systems. ESSAIM-CPS develops innovative, embedded, safe, and secure AI-based algorithms to ensure autonomous, efficient, and resilient multi-robot operations. By integrating robust control, cybersecurity, AI, and RF-based wireless communication systems, ESSAIM-CPS significantly advances CPS technology for both research and industry, accelerating France’s digital transformation by 2030. ESSAIM-CPS fosters interdisciplinary collaboration at LCIS-Grenoble INP, driving innovation and offering a rich educational environment for student training at both Grenoble INP-Esisar and IUT Valence, UGA, across embedded systems, robotics, and AI.
ACTIVITIES
PhD student working on “Dynamic exploration and containment for interacting hierarchical large-scale multi-agent systems” in collaboration with ONERA, Palaiseau
PhD student working on "Cross-layer intrusion detection in the wireless network of a drone swarm"
PhD / Postdoc working on “Securing and Enhancing the Resilience of AI-Based Embedded Control Modules for Autonomous Drone Squads in Hostile Environments”
Various internships on related topics throughout the duration of the project.
HT Do, F Blanchini, I Prodan: “A Low-Computational-Complexity Controller for Quadcopter Position Tracking with Guarantees of Stability and Convoluted Input Constraints,” European Journal of Control, 101236, 2025.
BM Bălăceanu, F Stoican, BD Ciubotaru, I Prodan: Derivative-free Kalman filtering for a six-wheeled rover, European Journal of Control, 101334, 2025
Cong Khanh Dinh, Vincent Marguet, Julian Barreiro-Gomez, Ionela Prodan, Carlos Ocampo-Martinez, Nicanor Quijano: “B-spline-Based Mechanism Design in Population Games for Distributed Evolutionary Dynamics Formation Control,” 2025 https://papers.ssrn.com/sol3/papers.cfm?abstract_id=5276334
CHAIR PRESENTATION
License:
Unless otherwise stated, all documents are shared under the Creative Commons BY-NC-ND 4.0 license.
You may view and share them for non-commercial purposes, without modification, and with appropriate credit to the authors.
Published on September 28, 2026 Updated on September 28, 2026
Core members
Co-chair: L. Morge-Rollet, an expert in RF communications and embedded machine learning,
N. Barbot, an expert in RFID, backscattering communication, and wireless power transfer
V. Beroulle, an expert in hardware safety and security
A. Mercier and O. Aktouf, experts in the security of decentralized systems
G. Blanchard, coordinator of APDISAR, emphasizes the importance of innovation;
J.-B. Cagnaert, an instructor at Grenoble INP-Esisar, is involved in developing new AI courses for all Esisar students and apprentices;
A.-P. Mirbaha, an instructor at Grenoble INP-Esisar, is involved in developing continuing education programs on securing embedded systems using AI;
C. Raievsky and A. Mercier from IUT Valence, UGA, who are involved in teaching distributed AI
Associate members
Sylvain Bertrand, ONERA Palaiseau, with expertise in robotics, distributed control and estimation, and machine learning.
Share the linkCopyCopiedClose the modal windowShare the URL of this pageI recommend this page:Available at this address:The page will then be accessible from your "My Favorites" menu.Stop the videoPlay the videoMutePlay audioChat: Have a question?Robo Fabrica ChatbotMatomo Traffic StatisticsX (formerly Twitter)